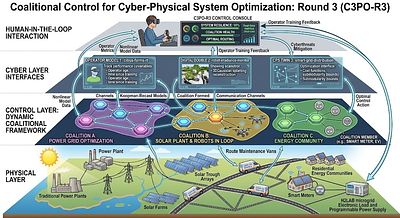
The C3PO-R3 project will enhance collaboration mechanisms among controllers in distributed control systems, endowing them with the capability to cooperate with heterogeneous entities such as robots or operators. In particular, the C3PO-R3 project aims to deepen the coalitional model predictive control framework to improve the interaction between these heterogeneous entities. We mainly plan to extend the coalitional framework to the field of nonlinear systems and to explore the use of alternative combinatorial optimization algorithms in this context. Also, we aim to deepen in the modeling of agents and their integration in the optimization problem in a holistic manner. Therefore, the project combines methods ranging from artificial intelligence to robotics, through the modeling of physical systems and the intelligent use of communication networks to establish coalitions of controllers based on their dynamic coupling, in such a way that the load of cooperation and computation in the system elements is reduced. The project has applicantions in large-scale systems such as power grids, traffic networks, solar plants and irrigation canals. In this regard, a member of Endesa belongs to the work team of the project, ensuring the transfer of knowledge to real world problems. Also, the results will also be validated in realistic simulators of large-scale systems that have been used in previous projects.
Principal Investigators: José María Maestre Torreblanca (PI) & Antonio Gallego (Co-PI).
Execution period: 01-09-2024 - 31-12-2027.
Funding: Financial support from MCIN/AEI/10.13039/501100011033 and ERDF/EU through project PID2023-152876OB-I00.
Principal Investigators: José María Maestre Torreblanca (PI) & Antonio Gallego (Co-PI).
Execution period: 01-09-2024 - 31-12-2027.
Funding: Financial support from MCIN/AEI/10.13039/501100011033 and ERDF/EU through project PID2023-152876OB-I00.